Karim Hammoud• Robotics Systems
51.52°N 0.13°W LDN --:--:-- FRAME 0000
[ 00 ] ● SYSTEM ONLINE — LIDAR SWEEP ACTIVE

KARIM
HAMMOUD

Engineering machines that walk, fly, sense and learn.

> ROBOTICS_

[ MSC ]UCL · Distinction
[ BENG ]AUB · GPA 3.83
[ FOCUS ]Humanoids · RL · Teleop
Scroll to initiate ↓
[ 01 ] PROFILE

I design, simulate and control robotic systems — from reinforcement-learning policies that teach humanoids to walk, to the sensors, firmware and models that let machines understand the world around them.

0%[ DETECTION ACCURACY ]MedAssist IoT tracker
0[ BILATERAL ARMS ]Franka Emika Panda ×2
0[ PAYLOAD ]Agricultural octocopter
0[ NATURAL FREQ ]MEMS gyroscope
[ 02 ] RESEARCH

Mission files

R-01 / HARDWARE + DATA PIPELINE

Egocentric capture headset & processing pipeline

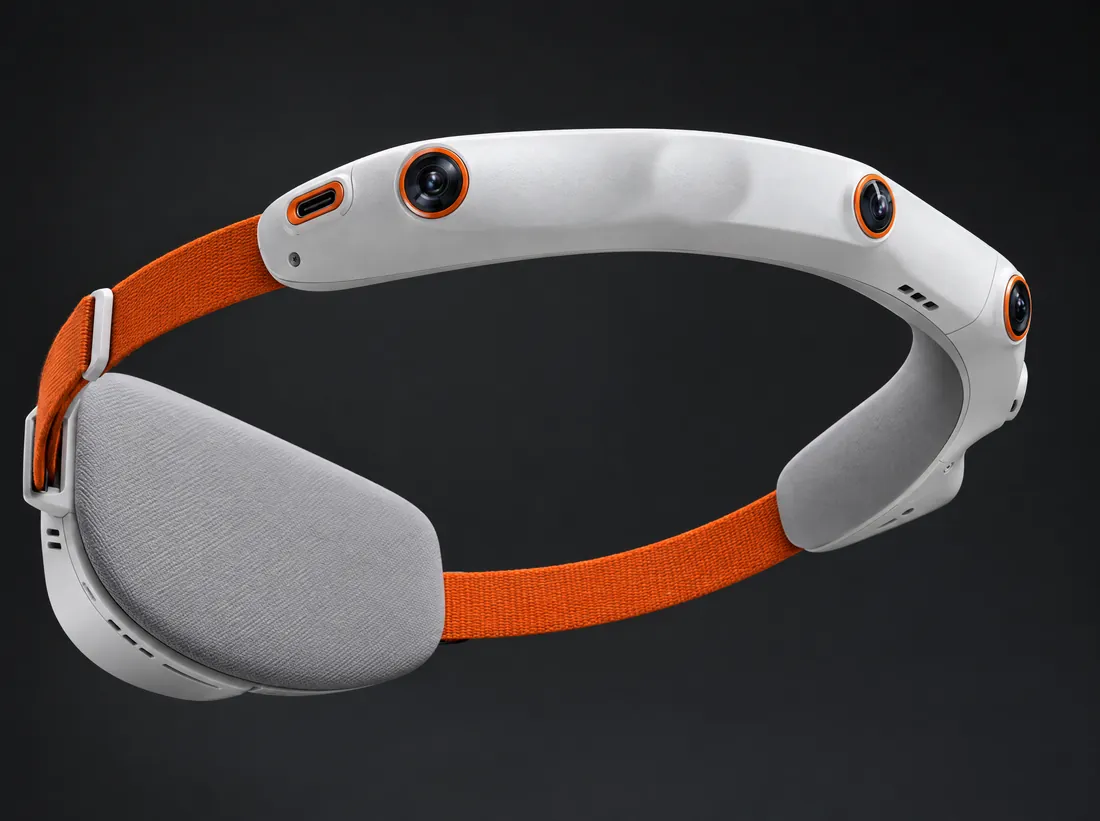
Designed a head-worn, four-camera capture headset that records egocentric data from human workers as they carry out real tasks — a first-person record of what their hands and bodies are doing, captured where the work actually happens.

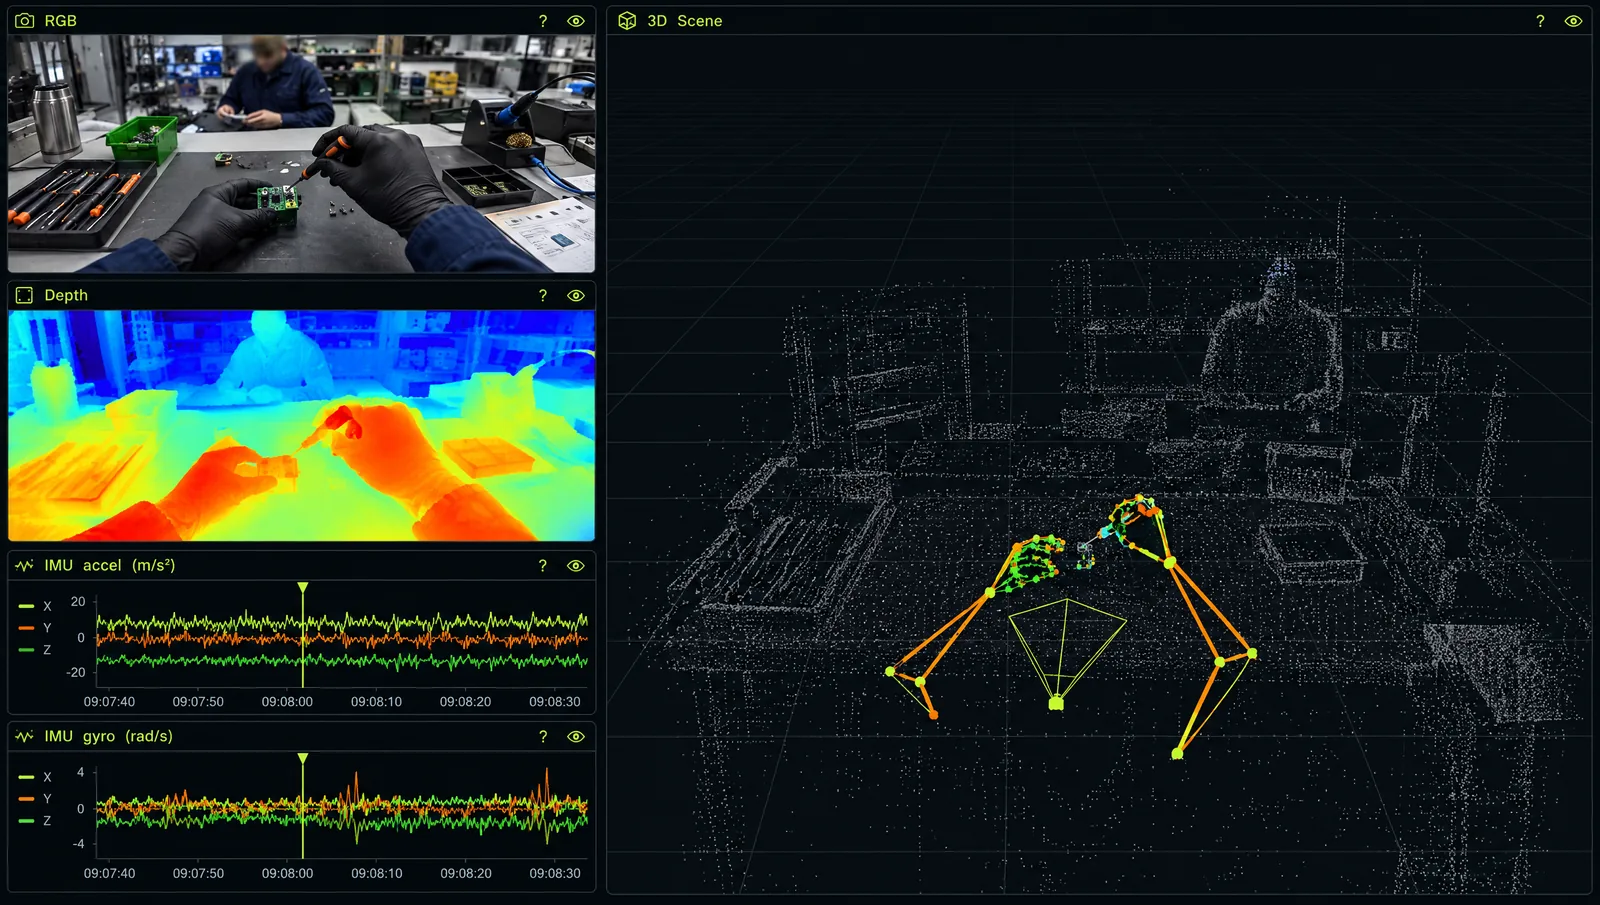
Recordings then run through a post-processing pipeline: PII scrubbing removes faces and identifying details, 3D pose estimation recovers body and hand motion, depth estimation adds per-frame scene geometry alongside the synchronised IMU streams, and an annotation pipeline labels it all into a training-ready dataset.
  • Hardware Design
  • Computer Vision
  • 3D Pose
  • Depth Estimation
  • Data Pipelines
Four-camera egocentric capture headset in white and orange
4 × CAM · EGOCENTRIC CAPTURE
Post-processing viewer showing the RGB feed with privacy blur, depth map, IMU plots and 3D pose in a point-cloud scene
POST-PROCESS · PII ▸ POSE ▸ DEPTH ▸ LABEL
R-02 / INDUSTRY ROLE

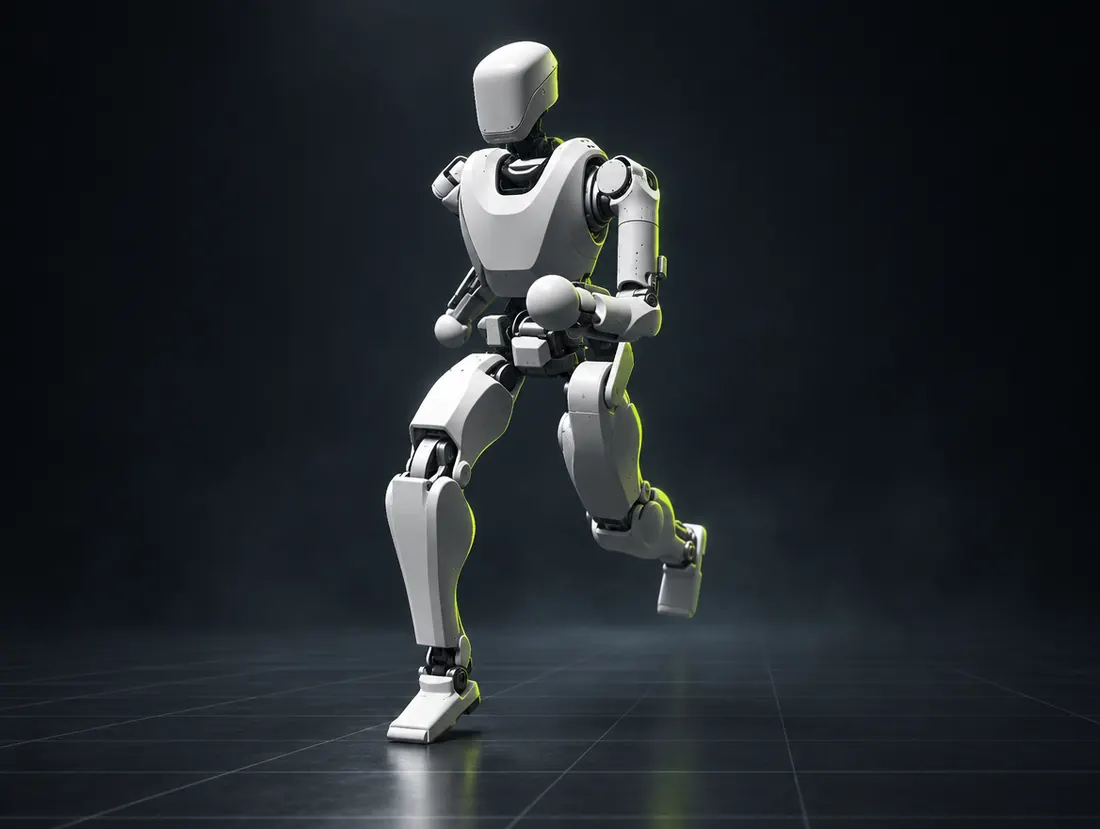
Humanoid locomotion through imitation-driven RL

Developed and deployed dynamic, robust reinforcement-learning policies for proprietary and commercial humanoid robots, enabling complex locomotion across varied environments.

Instead of hand-tuned rewards, a modified imitation-learning curriculum consumed kinematically feasible motion data captured in a VR simulation, where human operators intuitively guided a kinematically controlled robot. The result: robots that walk, balance and adapt — closing the gap between simulation and the real world.

  • Reinforcement Learning
  • Imitation Learning
  • Humanoids
  • Control
Render of a humanoid robot mid-stride
SIM ▸ REAL · POLICY v.FINAL
R-03 / MSc THESIS

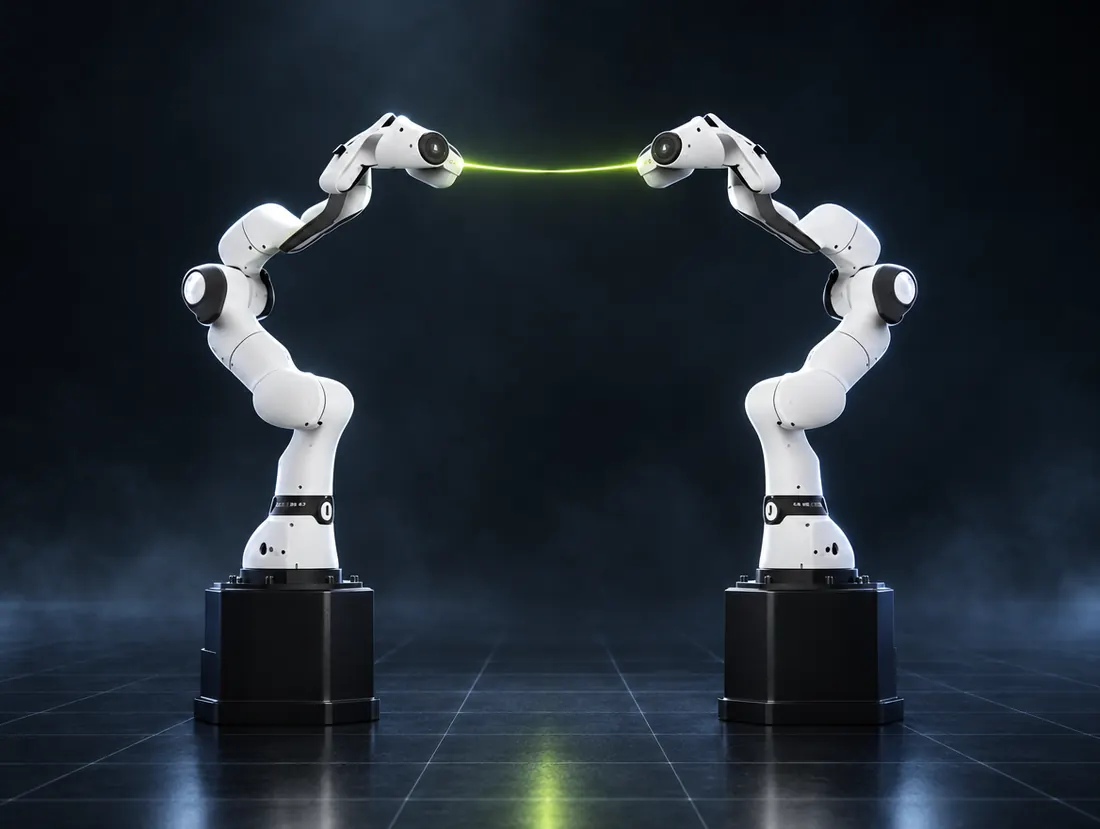
4-channel bilateral teleoperation with learned force

Built a 4-channel bilateral control system across two 7-DoF Franka Emika Pandas, letting two people perform robot-mediated, human-to-human tasks. Controllers in C++, ROS and Python switch between Cartesian and joint references depending on the motion transferred.

A PatchTST transformer was trained by imitation learning to generate human-like force profiles, and evaluated with a modified Turing test — it convincingly replicated human force dynamics.

  • C++
  • ROS
  • Python
  • MATLAB
  • Transformers
Read full thesis ↗
Render of two Franka arms linked in bilateral teleoperation
MASTER ⇄ SLAVE · 1 kHz
R-04 / PAPER

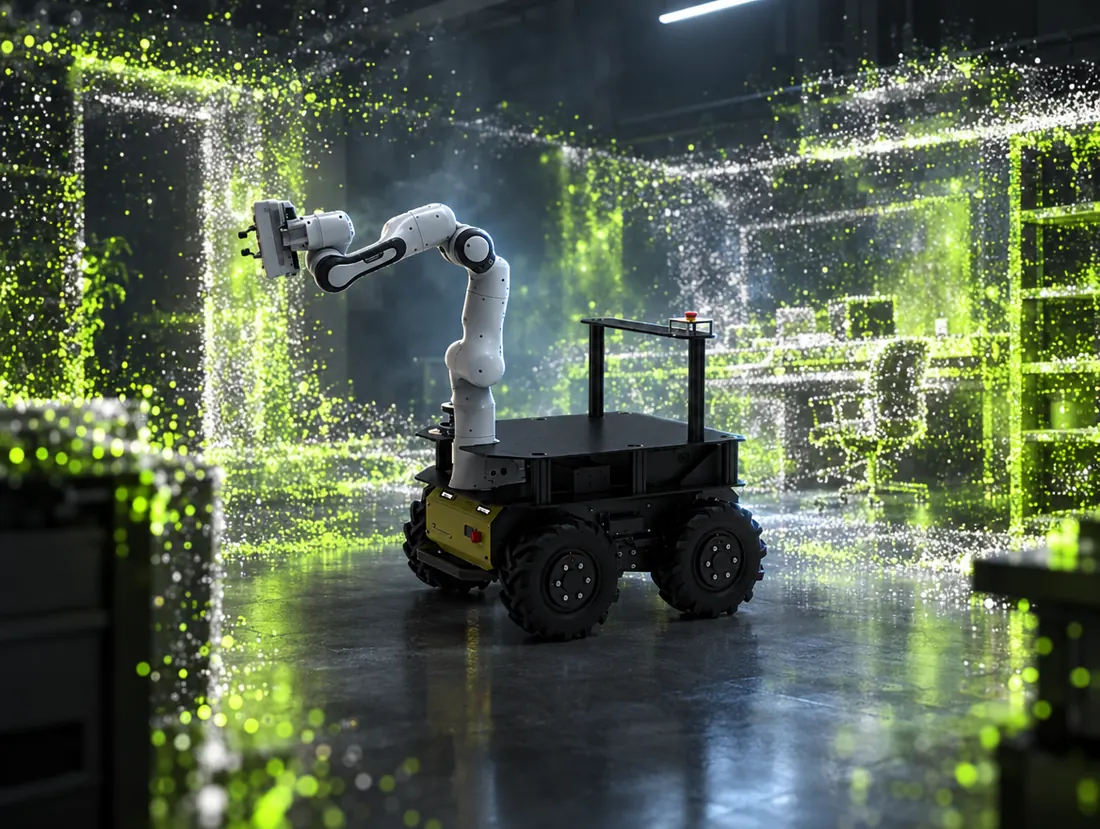
Mobile Franka, third-person VR

Enabled manipulation of a mobile Franka arm from third-person VR. Joystick control drives the mobile base to location; a Gaussian splat then reconstructs the scene for real-time, sim-to-real third-person manipulation of the arm.

  • C++
  • ROS
  • Python
  • Gaussian Splatting
  • VR
Read the paper ↗
Render of a Franka arm on a mobile base with a Gaussian-splat scene reconstruction
SPLAT RECON · LIVE
R-05 / BEng FINAL YEAR PROJECT

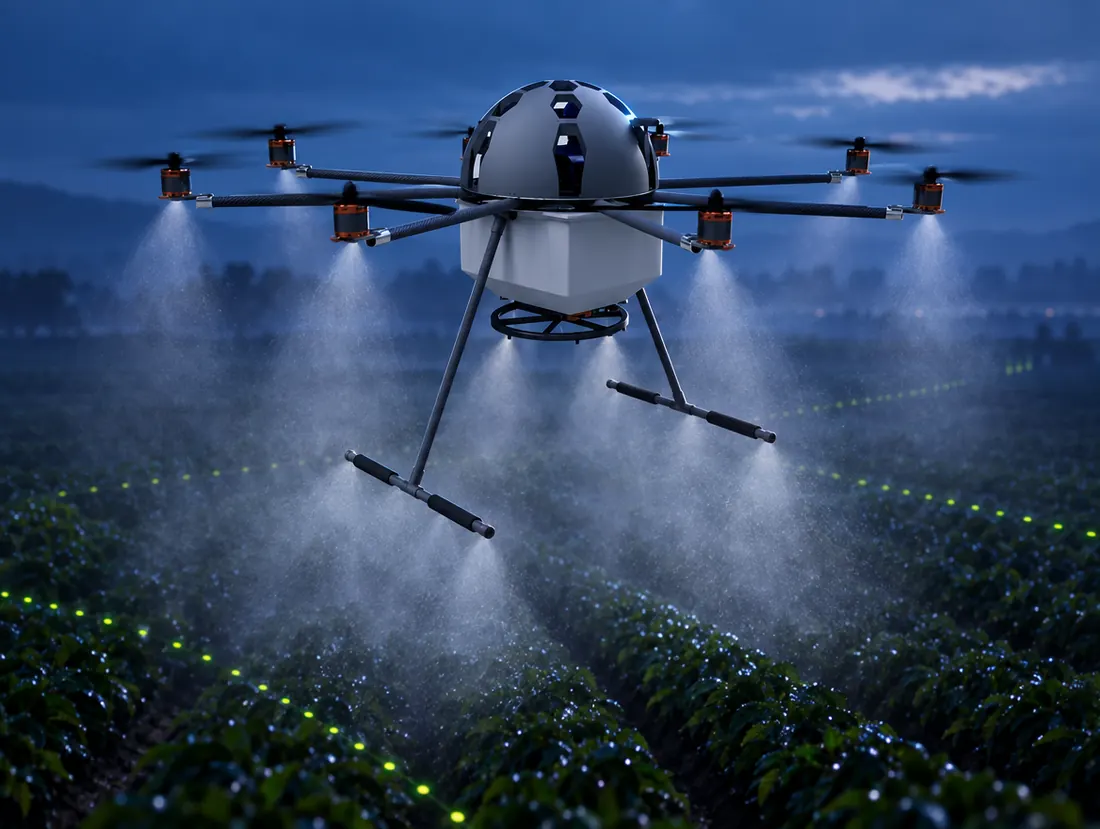
Autonomous agricultural octocopter

Designed and built a low-cost octocopter for pesticide spraying: automated path optimisation between user-defined waypoints, and a return-to-base routine for refilling. Navigation and control run on MAVLink; modular, lightweight construction carries a 4 kg payload.

Expand flight log

Simulation. ANSYS FEA evaluated structural integrity under operational stress. Modal analysis kept the airframe clear of damaging resonance; dynamic loading showed minimal deformation at maximum payload and thrust.

Testing. Field trials covered flight stability, propulsion and payload distribution. Manual and GPS-based autonomous path planning delivered precise, repeatable spray patterns, and simulated motor failures were absorbed by redistributing power for controlled landings.

Hardware. Composite airframe, high-efficiency brushless motors, a flight controller fusing GPS and IMU, a 5 L tank with a custom brushless pump and calibrated spray array, and carbon-fibre landing gear.

V2. Carbon-composite structure, CFD-refined aerodynamics and modular payload bays for broader agricultural and industrial use.

  • SolidWorks
  • MAVLink
  • ROS
  • ANSYS
Render of the agricultural octocopter spraying a field
PAYLOAD 4 KG · RTB ENABLED
[ 03 ] ARCHIVE

Projects

[ 04 ] TRAINING DATA

Education

UCL · LONDON, UK

MSc Systems Engineering for the Internet of Things

▲ Graduated with Distinction

  • Embedded Systems Design
  • Sensor Systems
  • Real-world Multi-agent Systems
  • Robotic Control Theory
  • Speculative Design
AUB · BEIRUT, LEBANON

BEng Mechanical Engineering, Minor in Bioengineering Design

▲ GPA 3.83 / 4.00 · Cum Laude · Dean's Honor List

  • Control Systems
  • MEMS
  • Optimization
  • Thermodynamics
  • Mechanics of Machines
  • CAD/CAM
  • Heat Transfer
  • Biomaterials & Medical Devices
  • Tissue Engineering
[ LANGUAGES ] EnglishArabicFrenchSpanishPortuguese
[ 05 ] OPEN CHANNEL
Get intouch↗